


I build end-to-end real-time control and machine-learning systems across custom hardware and software: embedded firmware, wireless communication, computer vision, and reinforcement learning.
Recent projects: two from-scratch quadcopters with custom ESP32 flight controllers. KattVis uses onboard stereo vision for GPS-free motion and position estimation, while PidraQRL has a live RL agent tuning PID gains in real time on physical hardware.
🏆 YSEA Award Winner (2026) – Received the Most Outstanding STEM Exhibit at the Unga Forskare National Final (Sweden's Championship for Young Researchers).


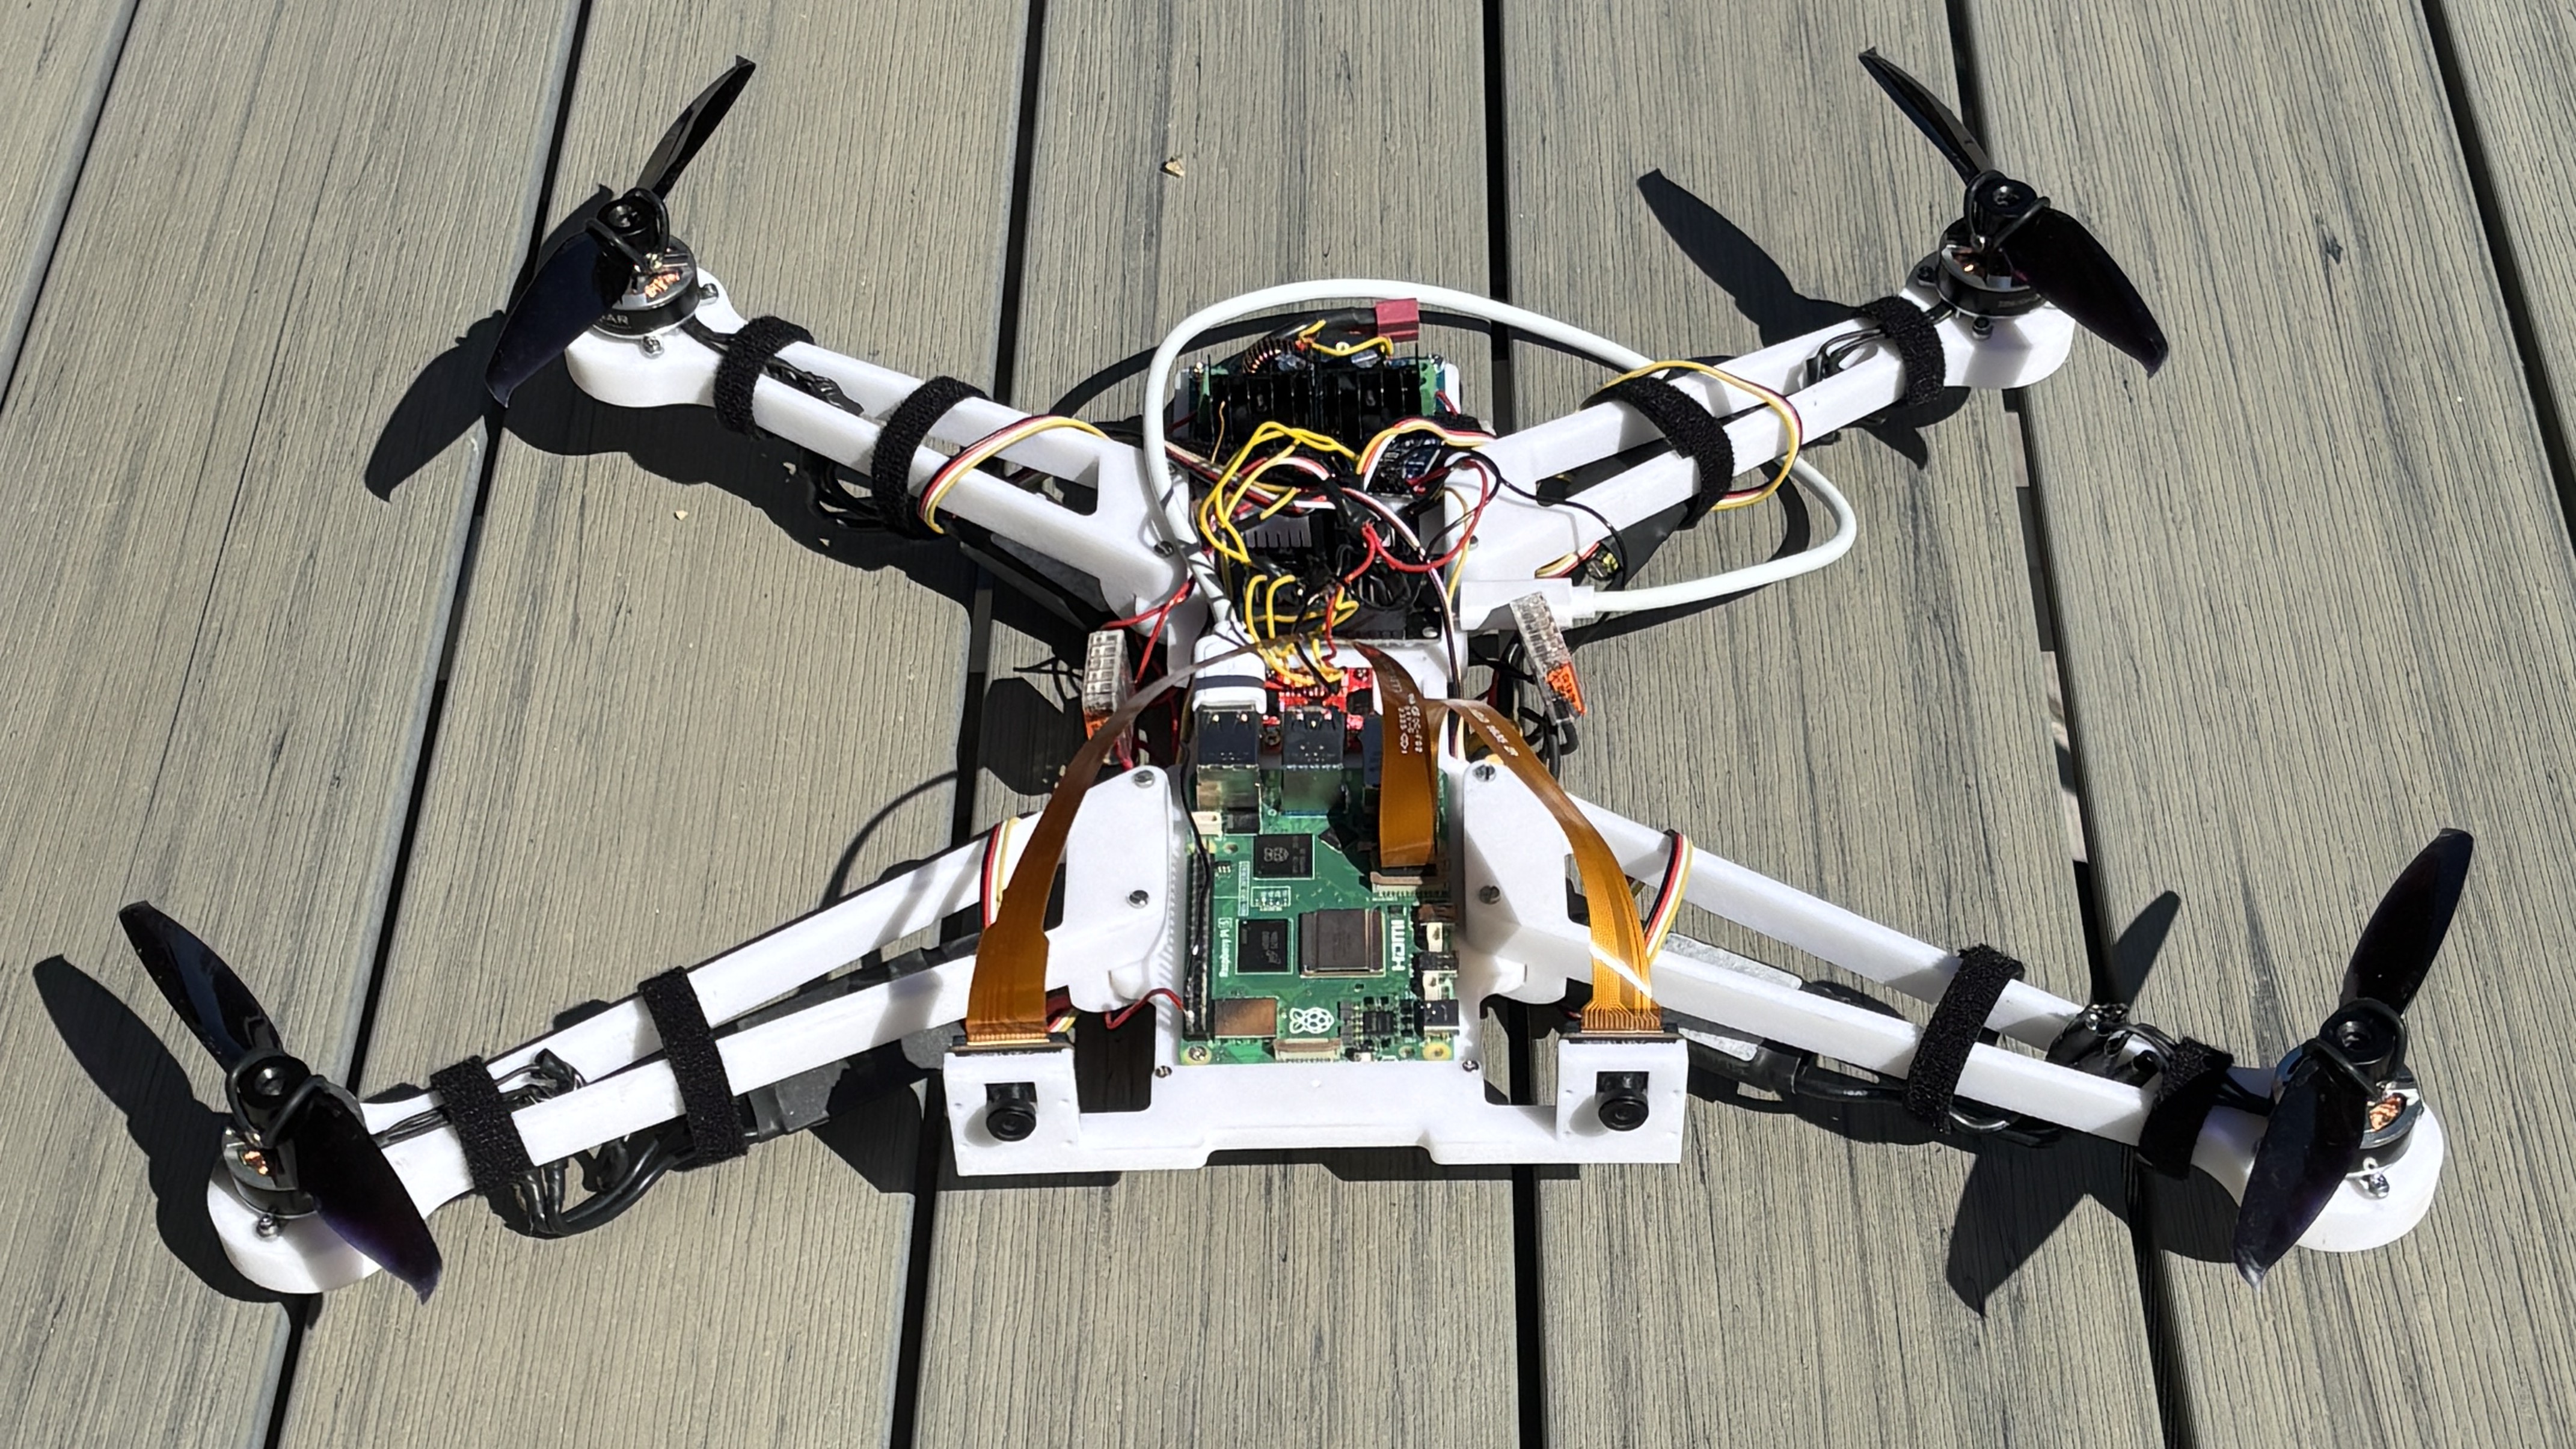
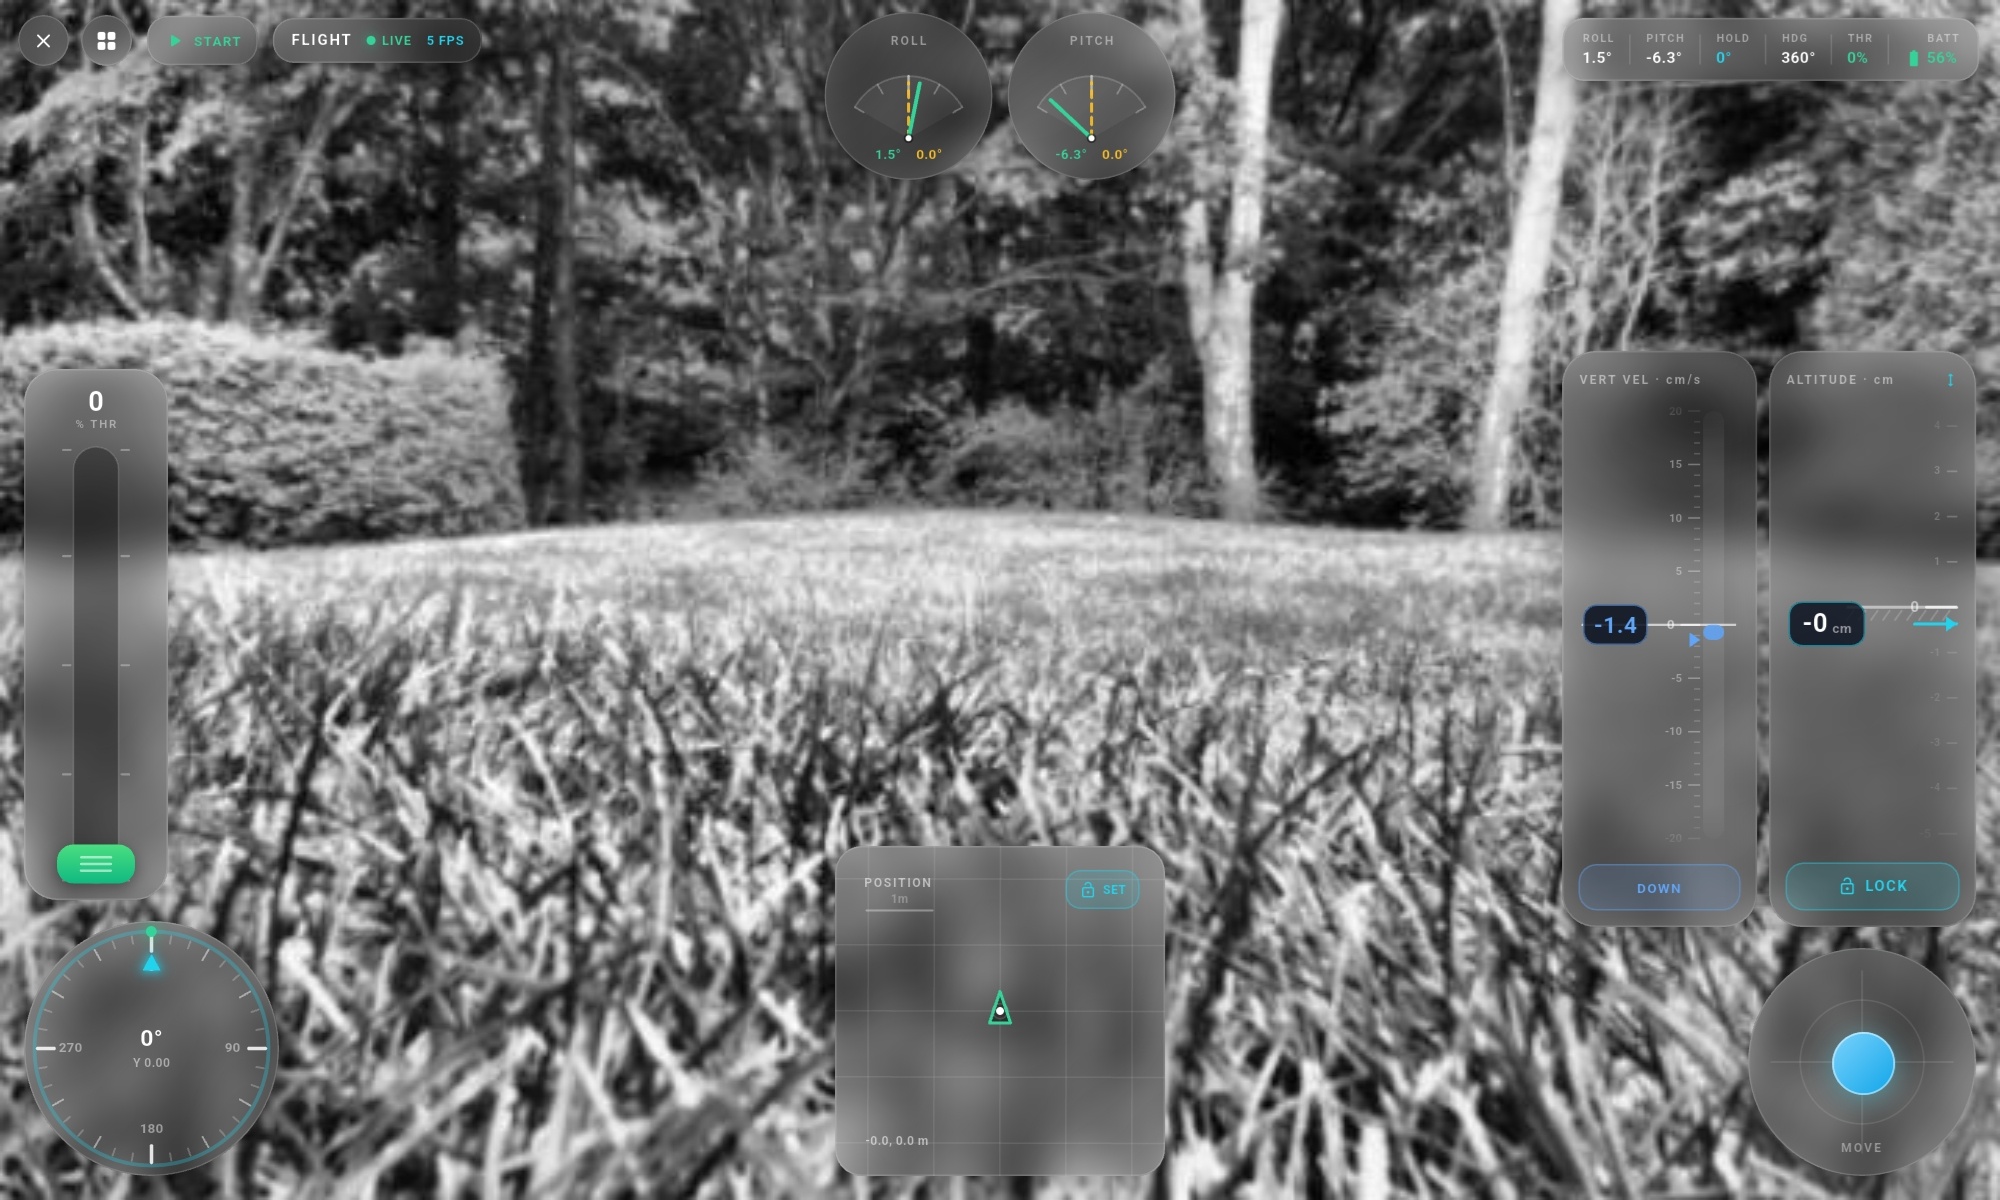
A stereo-vision quadcopter built from scratch, flying without GPS or a barometer, using onboard stereo cameras and an IMU instead.
 |
 |
- Custom ESP32 flight controller with a cascaded PID loop at 250 Hz, running independently of the vision workload
- Deadcat airframe with a tuned front/rear roll-mix to compensate for the front motors' extra torque leverage
- Raspberry Pi 5 running an onboard stereo-vision and visual-odometry pipeline (dual OV9281 global-shutter cameras, 12 cm baseline) for GPS-free motion and altitude estimation
- Custom Flutter ground station with the CAD-modeled airframe rendered live, PID tuning, a per-motor test mode, and built-in stereo calibration
- Prototyped the stereo pipeline in Unity before buying the physical cameras, to prove the approach out first
- Custom nylon airframe designed in Fusion 360, manufactured and sponsored by PCBWay
Status: 10 seconds of controlled flight demonstrated so far. Altitude hold is functional and being tuned.


A quadrotor built entirely from scratch with a live SAC reinforcement learning agent tuning roll-controller gains in real time, and a Unity HDRP digital twin mirroring live telemetry.
 |
 |
- Custom ESP32 flight controller with cascaded PID, Madgwick AHRS, and biquad filters (250 Hz loop)
- Full wireless chain:
Flutter app → BLE → Raspberry Pi → LoRa → ESP32(+ direct BLE for RL) - SAC RL agent tuning PID gains in real time on the physical drone, no sim-to-real transfer
- Custom single-axis test rig for safe RL training with live propellers
- Unity HDRP digital twin with Fusion 360 models, mirroring live IMU telemetry over UDP
Winner of the Yale SEA Most Outstanding STEM Exhibit at the Unga Forskare 2026 National Final.
What the jury said
"The project stands out through a very high level of technical ambition. The custom-built flight controller, the distributed communication chain, and the well-designed failsafe solution demonstrate a deep understanding of real-time systems, control theory, and system safety. The methodology is exemplarily clear and reproducible."
— Translated research jury feedback, Unga Forskare 2026
"In this project, the team members refused to take any shortcuts whatsoever. By rejecting ready-made frameworks and instead building everything from scratch, from communication to software, this work has demonstrated a technical dedication beyond the ordinary."
— Winners catalogue, Unga Forskare 2026 (translated)
Press and links


Generates a playable Geometry Dash level from any song using beat detection and physics simulation.
 |
 |
- Analyzes audio to detect beats and uses them to drive level generation
- Cube mode simulates ballistic arc physics reverse-engineered from observed in-game behavior
- Wave mode generates a diagonal path with rails and ramps sampled by arc length
- Reverse-engineered the
.gmdformat used by the GDShare mod to write valid level files importable directly into GD - PyQt GUI with synchronized audio waveform and level geometry preview

Software Developer, CPAC Systems · 2021 to 2025 (recurring)
Five paid internships starting at age 15 across four years, building internal tools and simulators in C#, Python, and Unity.
- Optimized a Unity simulator, doubling frame rate
- Built a Python diagnostics tool adopted by senior engineers for root cause analysis
- Built a license management service (HTML, CSS, JS)
- Developed machine simulations with custom mesh generation in Unity
- Refactored Perl codebases and worked on a web application (HTML, SCSS, TypeScript)
| Area | Skills |
|---|---|
| Embedded systems | C++, Arduino, PID control, IMU data filtering and handling, Fusion 360 |
| Simulation & Graphics | Unity, C#, procedural generation (noise combining), Blender |
| Computer Vision | OpenCV, stereo vision, visual odometry, feature tracking, camera calibration |
| App | Flutter (Dart), React, Python |
| AI | Reinforcement learning, YOLO, Torch, dataset generation |
| Languages | Swedish (native), English (fluent), French (basic) |